Robot soccer Active
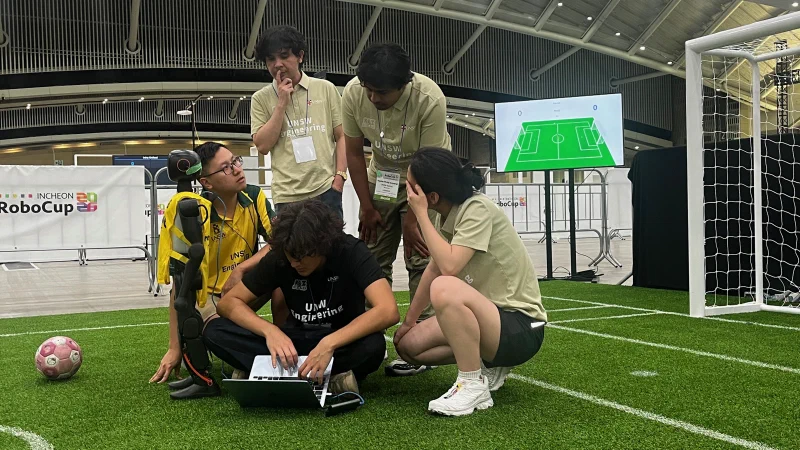
rUNSWift
Humanoid robot soccer as a testbed for perception, motion and autonomous team behaviour.
Explore rUNSWiftUNSW Computer Science and Engineering
Physical platforms, autonomous teams and software that turn research questions into experiments.
These projects illustrate work across robot learning, reasoning, perception and interaction. Each entry identifies its lifecycle status and links to a project source for further detail. Historical platforms are listed separately from active work.
Robot soccer Active
Humanoid robot soccer as a testbed for perception, motion and autonomous team behaviour.
Explore rUNSWiftService robotics Active
Planning, perception, manipulation and world modelling for robots working in home environments.
Explore rUNSWeepSearch and rescue robotics Active
Autonomous exploration, mapping and victim identification with a Unitree Go2 quadruped in simulated disaster environments.
Explore RoboCup RescueRobot platform Historical
The humanoid platform used by earlier generations of rUNSWift.
Explore NAO robot soccer platformIndustrial robotics Historical
A 2024 project description for autonomous navigation and manipulation on a simulated factory floor.
Explore UNSW@Work