Autonomous robot soccer
rUNSWift brings together students and researchers to build robots that play soccer autonomously. The task connects vision, localisation, motion, decision-making and coordination in a single physical system.
Building a complete autonomous system
The original team material identifies vision, motion, localisation, behaviours, communication, system architecture, tooling and robot maintenance as connected areas of work. On a soccer field, progress in one component only helps when it works with the rest of the system.
The Standard Platform League used common hardware to focus competition on robot software. The team’s history and robot timeline trace the earlier AIBO and NAO generations and preserve competition records.
A new generation of robots
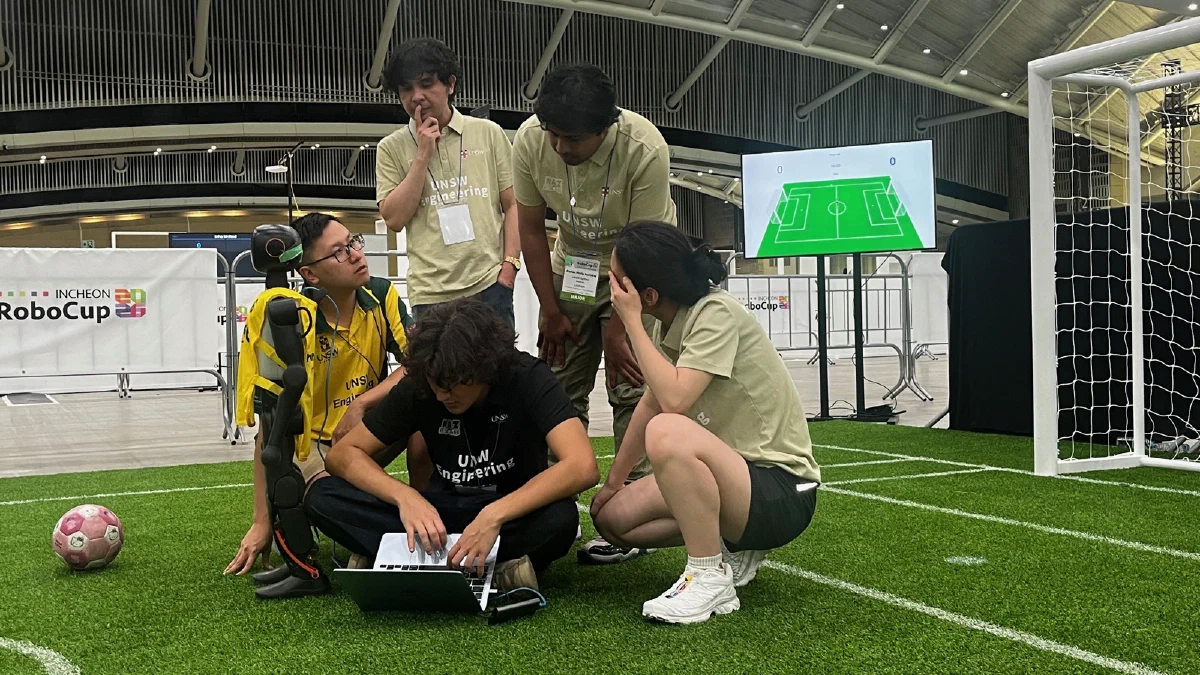
At RoboCup 2026 in Incheon, rUNSWift competed with Booster K1 humanoid robots for the first time. The transition from NAO robots required changes to locomotion, localisation, game play and ROS 2 software. Competition provides a demanding test of how these components work together.
Read the 2026 team description paper or explore the RoboCup archive.
Get involved
For student project enquiries, use our official UNSW contact route.