The 2024 project record
The original GitLab site described UNSW@Work’s aim of developing a holonomic mobile robot for RoboCup@Work 2024. The proposed system would navigate a simulated factory floor, collect objects and deliver them using a robotic arm.
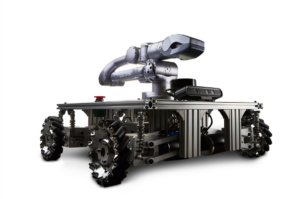
The project brought together LiDAR and depth sensing, SLAM-based navigation and computer vision for recognising objects. Its research setting connected perception and mapping with physical manipulation in an industrial-style task.
This entry preserves the 2024 project description. It does not establish the team’s current activity or assert that the competition goals were achieved.